Hardware that ships with its own evidence.
Every board is characterised on our dynamometer and leaves with the telemetry software that produced the numbers.
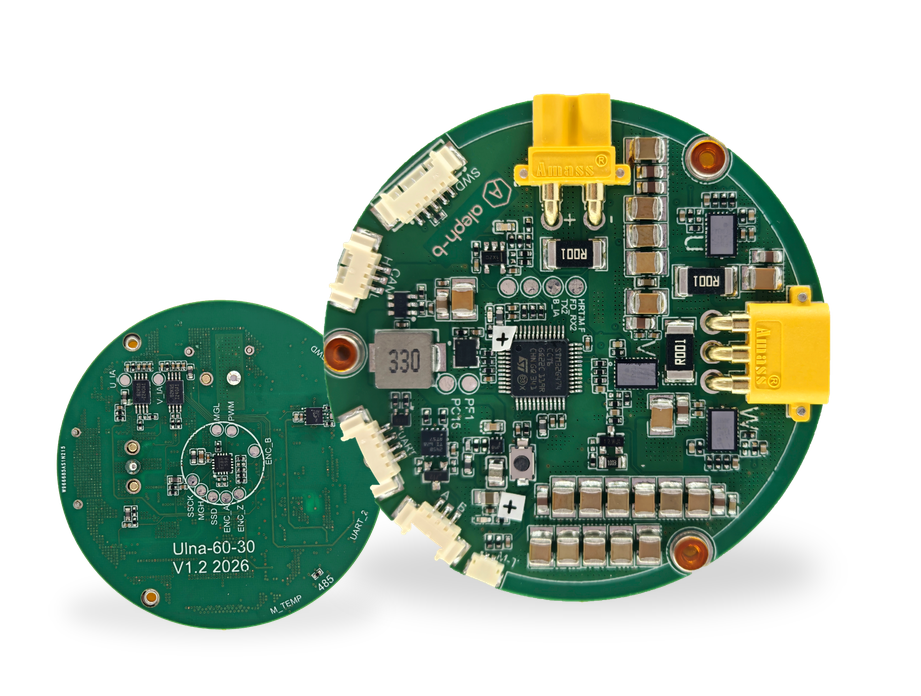
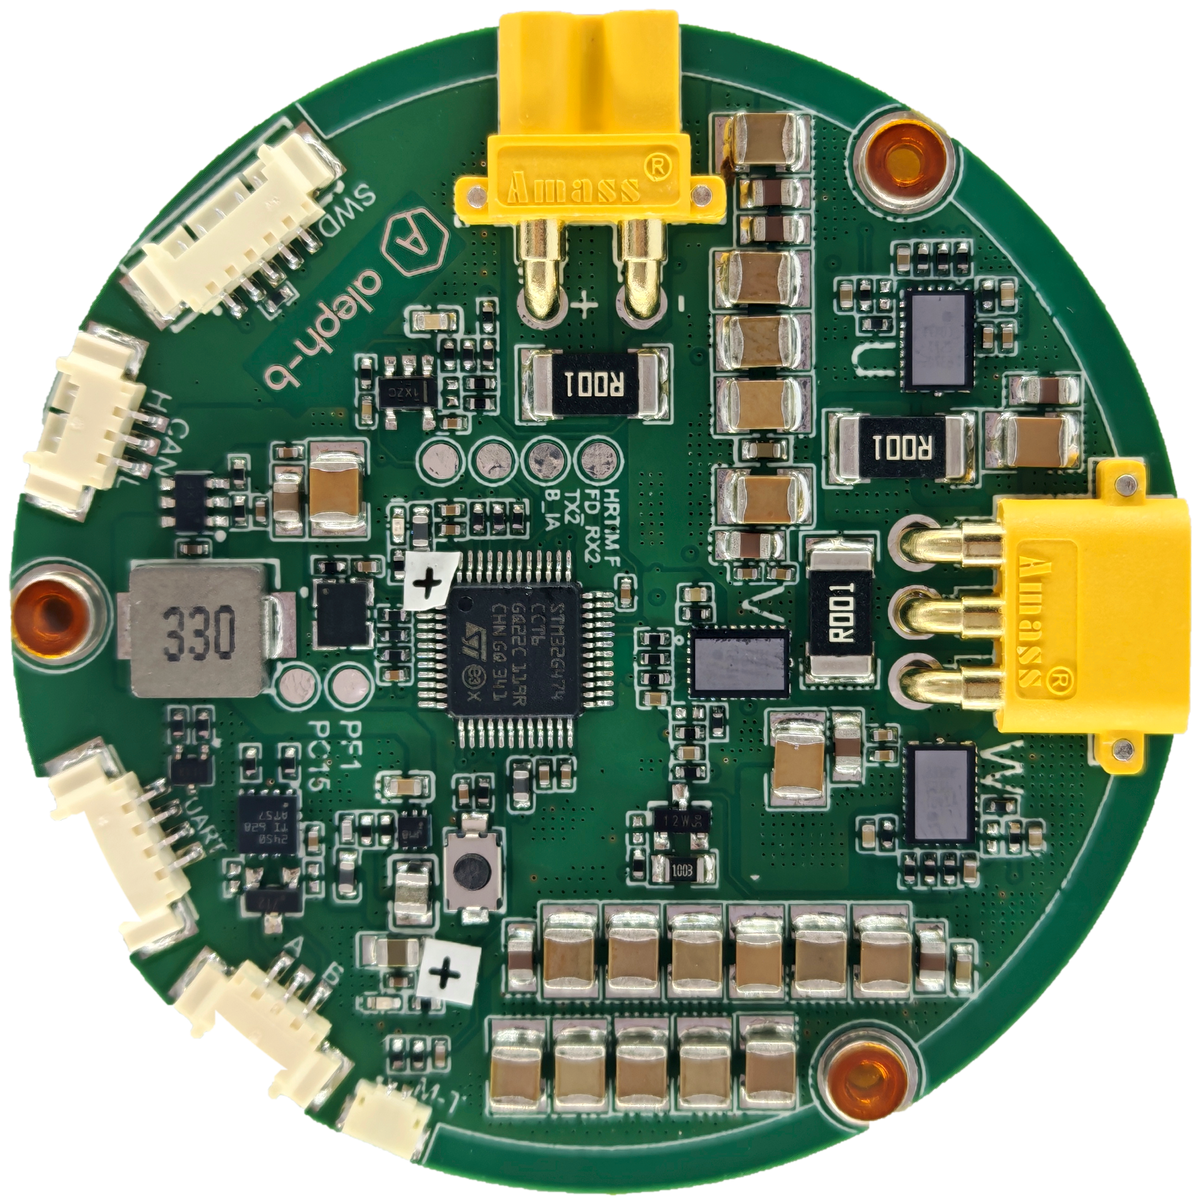
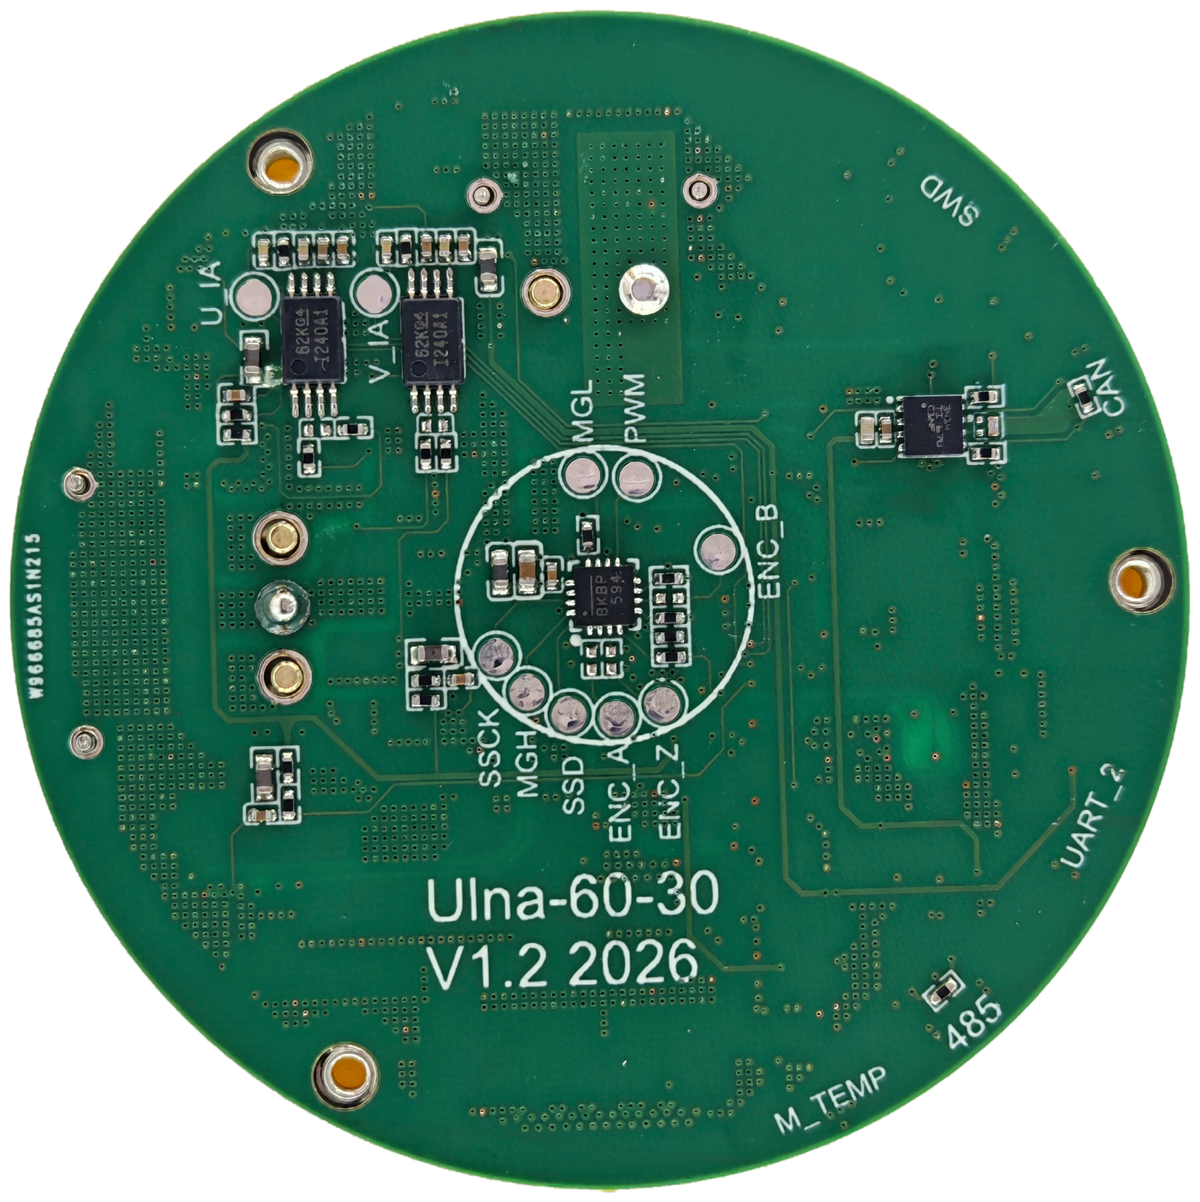
GaN servo drive
ulna-60-25
A 60 V, 25 A peak three-phase GaN servo drive built around the STM32G431, three EPC23102 GaN half-bridges and a 14-bit MA732 magnetic encoder. Sensored FOC at 100 kHz PWM with 20 ns dead time, CAN FD.
$349.00 USD
Out of stock · rev 1.2
⏱Lead time: 12 weeks from order
Drive specification
DC bus
60 V
Power stage
Three EPC23102 GaN half-bridges
Controller
STM32G431
Position sensing
MA732, 14-bit magnetic
Control
Sensored field-oriented control
Switching headroom
100 kHz
Interfaces
CAN FD
Validation
Dynamometer characterised
ulna-60-25 documentation
PDFDatasheet, rev 1.2
Electrical, thermal and mechanical specificationQuick start guide
Unbox to first spin, wiring and safe power up sequenceTelemetry software manual
Live data screen, logging and exportDynamometer validation report
Measured torque, efficiency and thermal data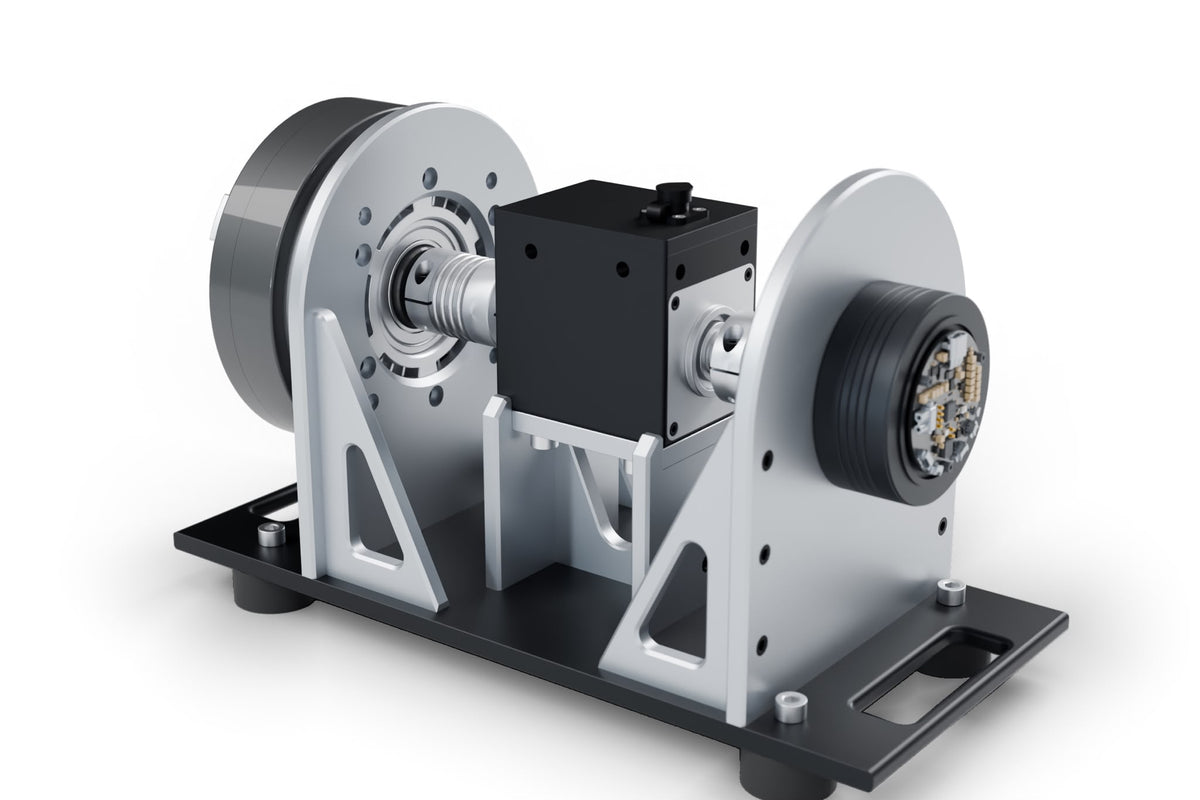
Bench equipment
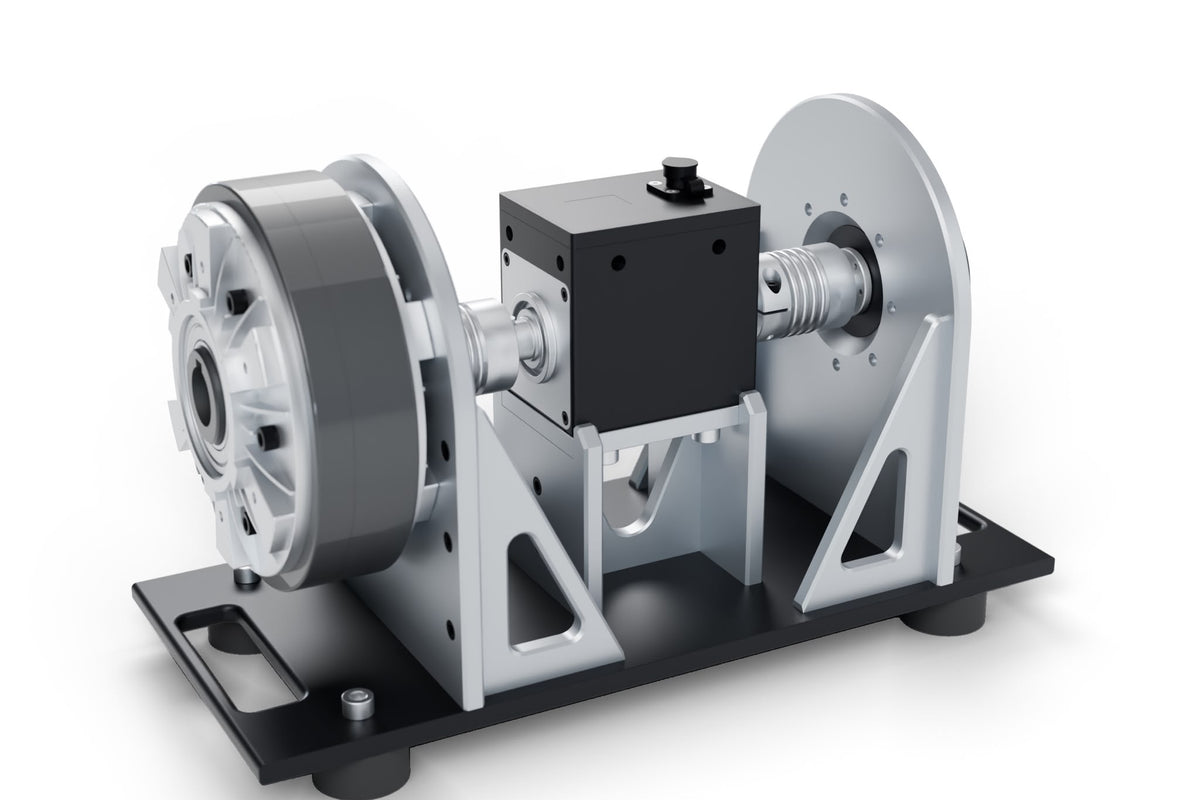
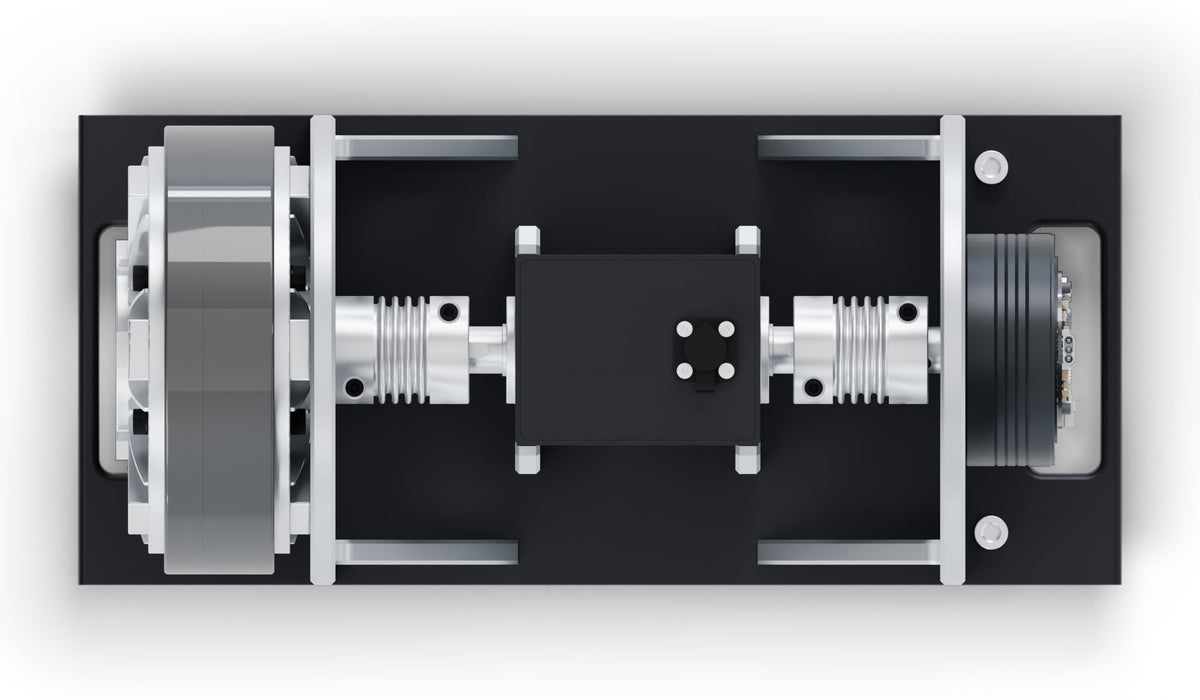
25 Nm dynamometer
The stand we built to characterise every drive we ship. Inline torque sensing, a magnetic powder brake under closed loop control, and zero backlash bellows couplings on a rigid frame. We build these to order because we already build them for ourselves.
- Repeatable torque and speed characterisation
- Configured to your motor envelope and mounting
- Same stand behind every ulna specification we publish
Dynamometer specification
Frame rating
25 Nm
Torque sensor
Inline rotary, 20 Nm calibrated range
Load
Magnetic powder brake, closed loop controller
Couplings
18 mm bellows, zero backlash
Shaft centreline height
122.0 mm (4.80 in)
Measured channels
Torque, speed, brake current
Configuration
Built to order, quoted per application
Different application, different stand
Tell us what you need to measure.
Torque class, speed range, motor mounting and instrumentation all change the build. We quote per configuration rather than selling one stand that half fits everyone.