ulna-60-25
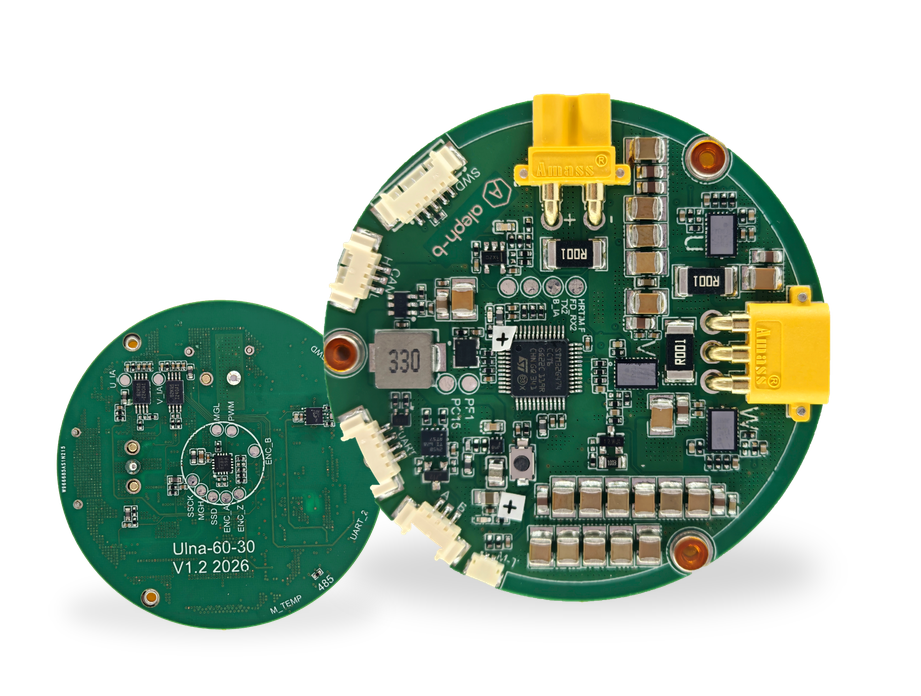
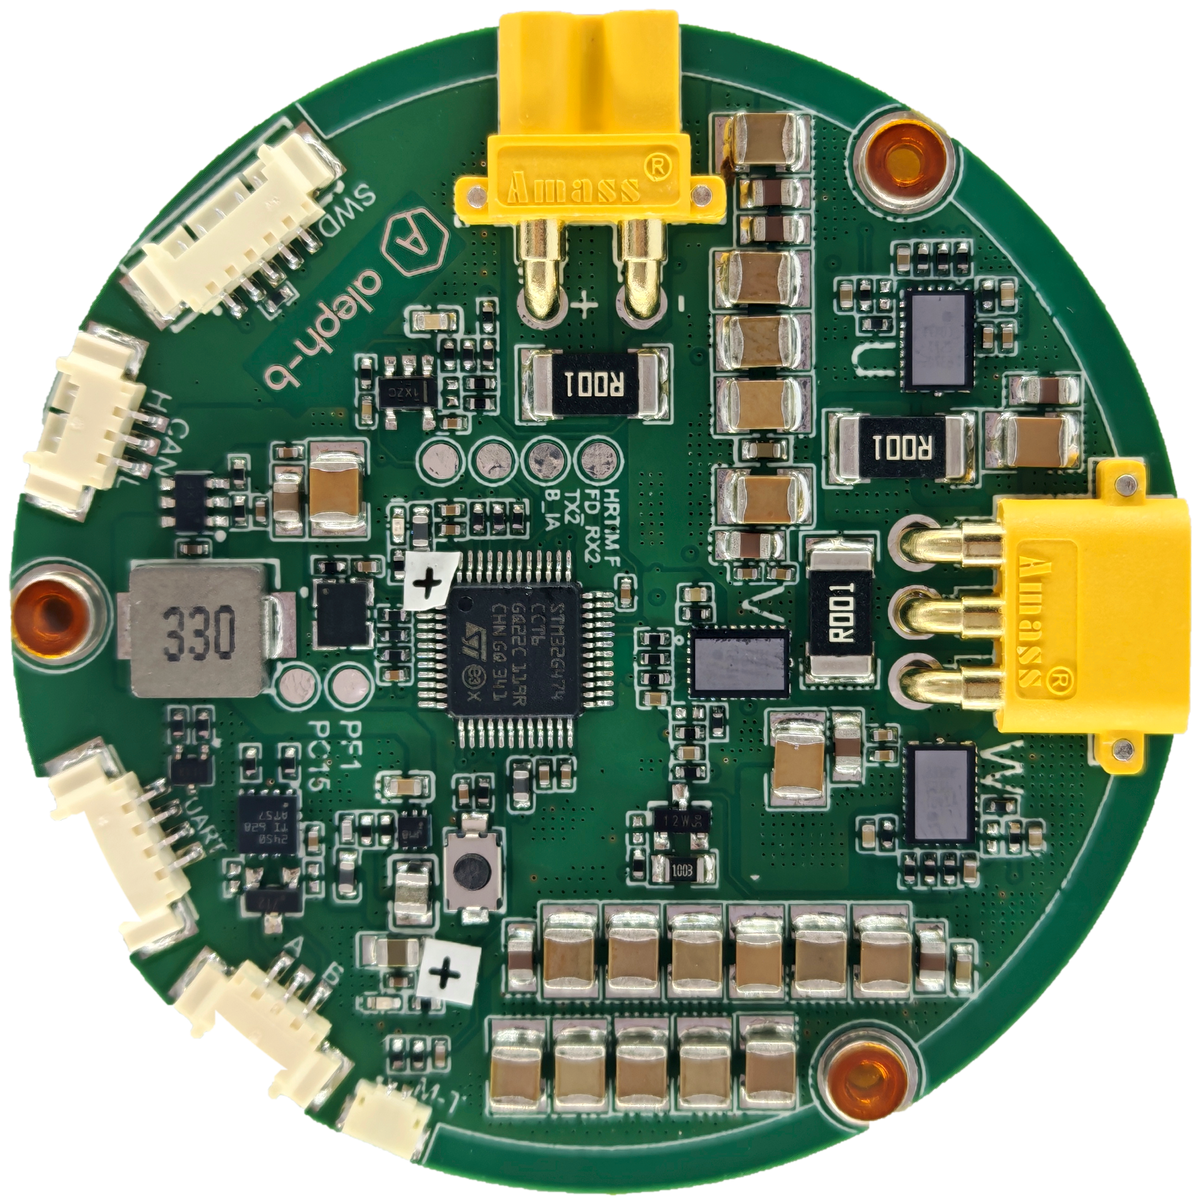
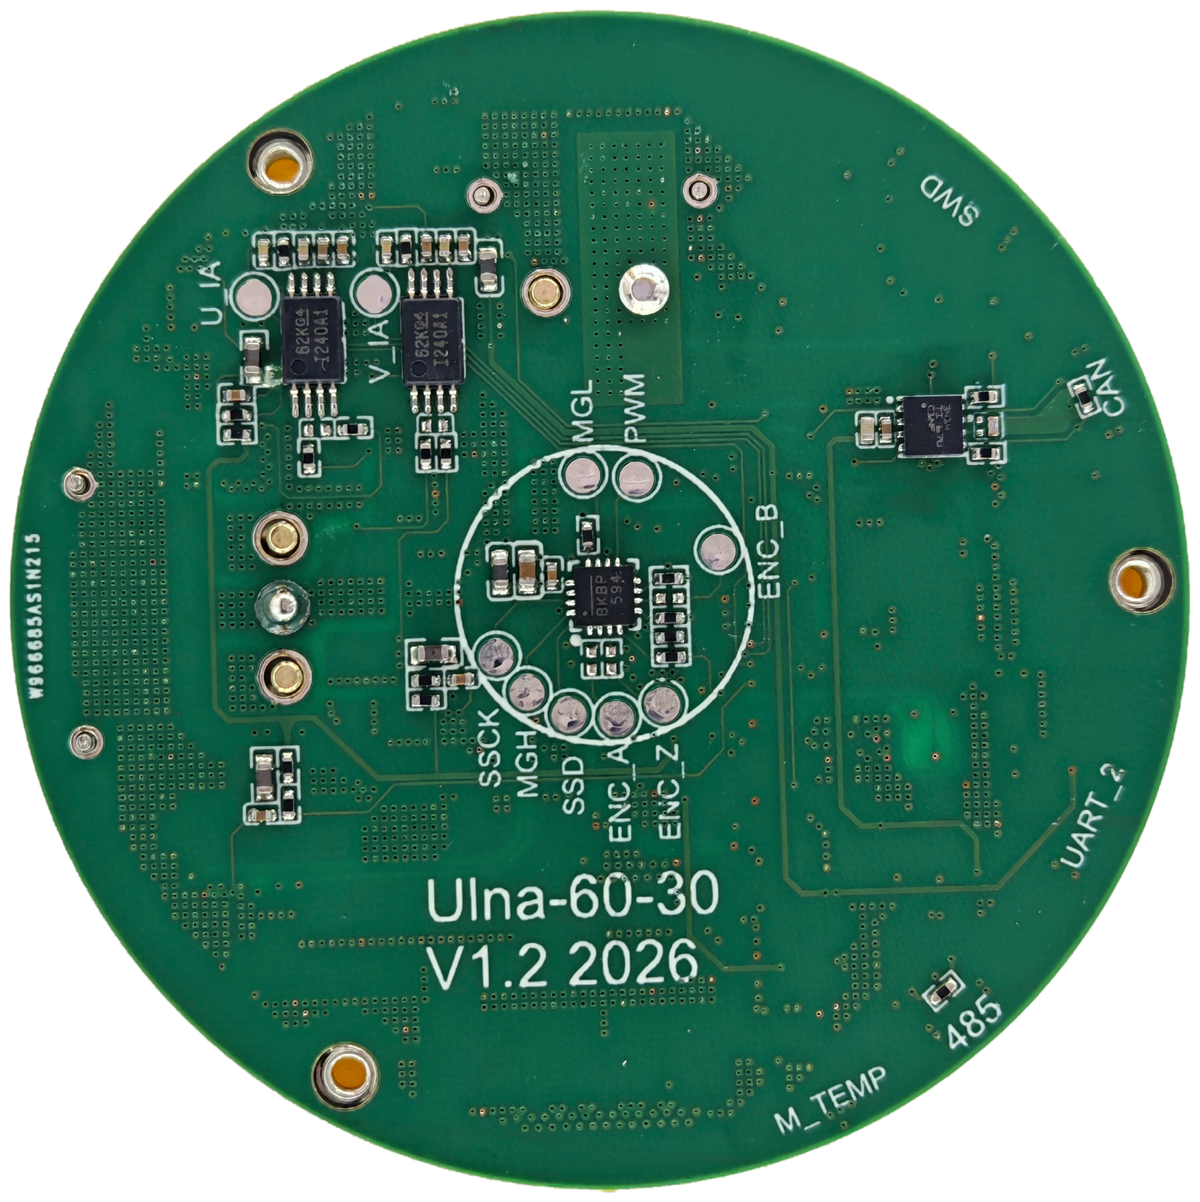
A 60 V, 25 A peak three-phase GaN servo drive built around the STM32G431, three EPC23102 GaN half-bridges and a 14-bit MA732 magnetic encoder. Sensored FOC at 100 kHz PWM with 20 ns dead time, CAN FD.
Datasheet, rev 1.2
Electrical, thermal and mechanical specificationQuick start guide
Unbox to first spin, wiring and safe power up sequenceTelemetry software manual
Live data screen, logging and exportDynamometer validation report
Measured torque, efficiency and thermal dataWhat ships, and what it does.
A 60 V, 25 A peak three-phase GaN servo drive built around the STM32G431, three EPC23102 GaN half-bridges and a 14-bit MA732 magnetic encoder. Sensored FOC at 100 kHz PWM with 20 ns dead time, CAN FD. Ships with our telemetry software, ready for the bench.
Software and telemetry, out of the box.
This is not just a board. It ships with host software that streams real-time telemetry, tunes control loops live, and configures the drive over the bus, so you spend your time on the robot, not the bring-up.
See inside the loop
Stream phase currents, position, velocity, bus voltage and temperature in real time over CAN-FD or RS-485.
Tune without reflashing
Adjust FOC gains, limits and modes on the fly from the host tools and watch the response immediately.
Script and integrate
A clean command and telemetry protocol with a host SDK, so the drive drops into your own control stack and test rigs.