25 Nm dynamometer
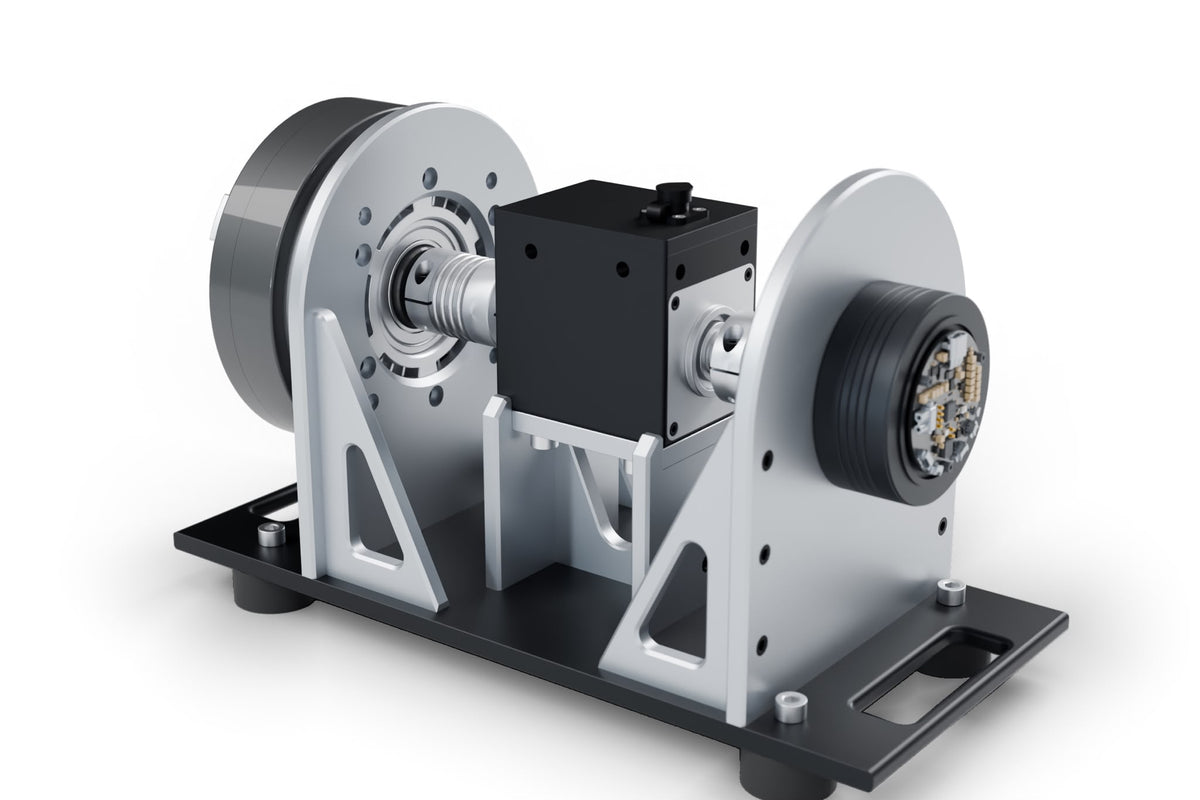
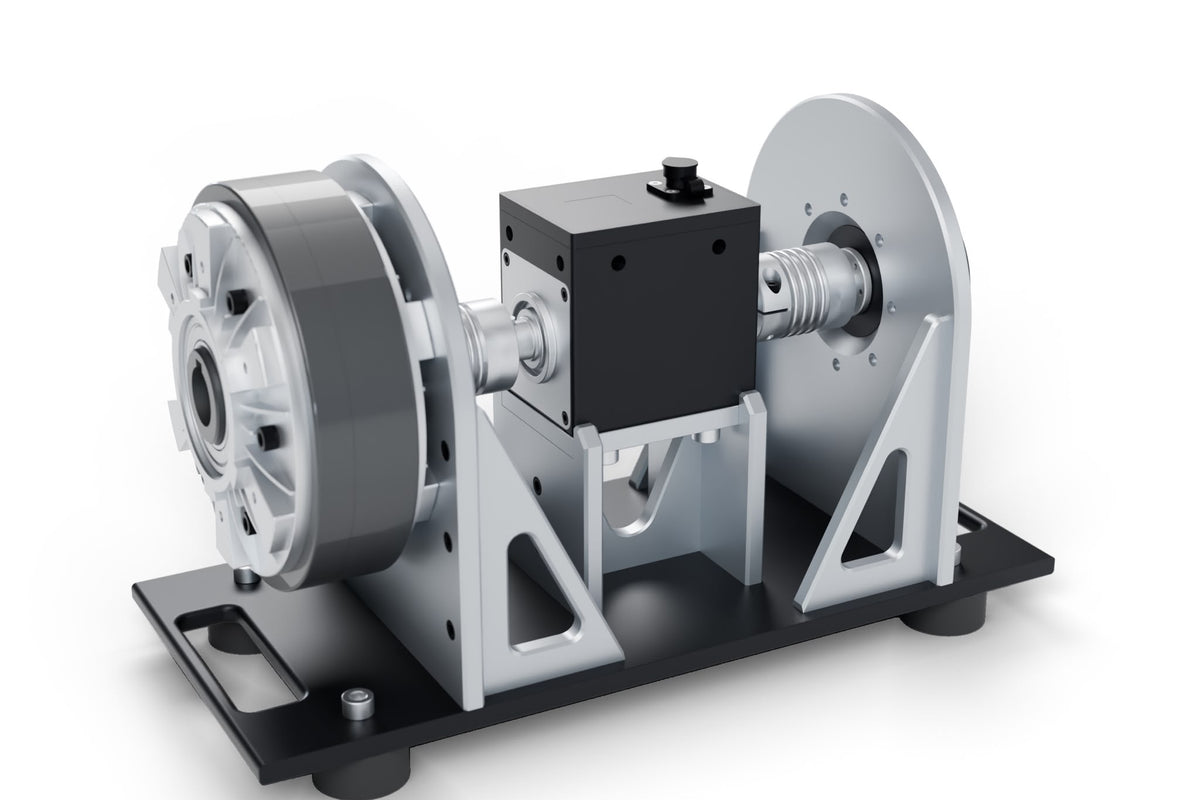
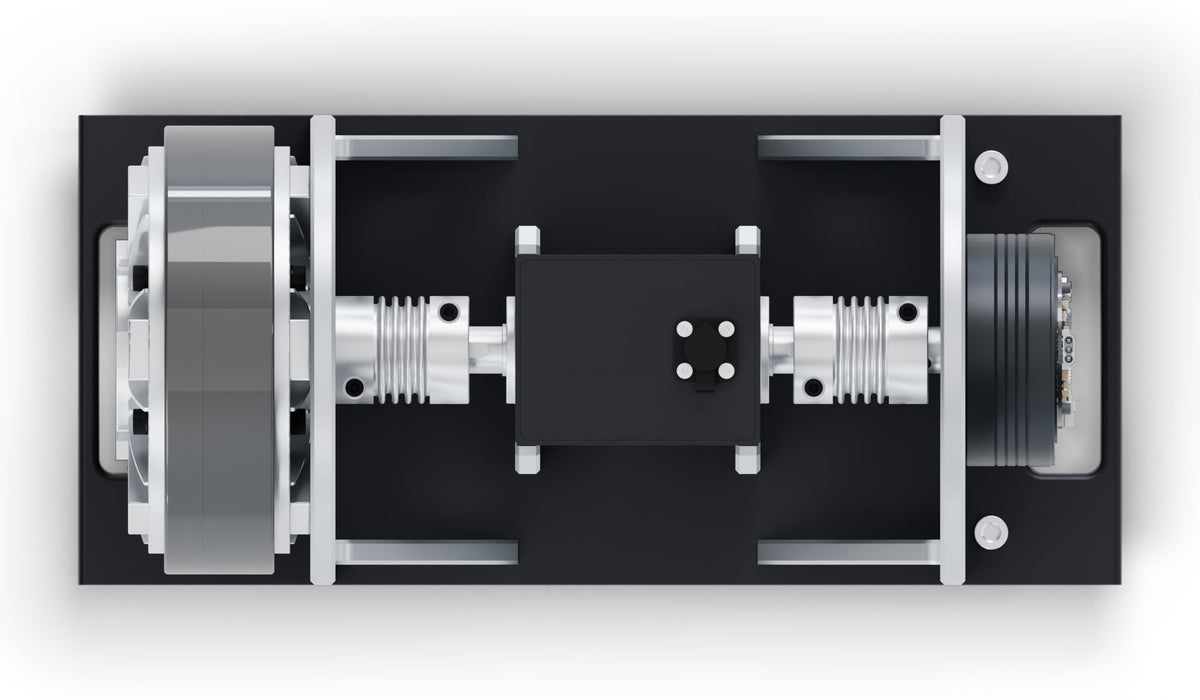
The stand we built to characterise every drive we ship. Inline torque sensing, a magnetic powder brake under closed loop control, and zero backlash bellows couplings on a rigid frame. We build these to order because we already build them for ourselves.
Configuration worksheet
What we need from you to quote a stand25 Nm dynamometer spec sheet
Frame, sensor range, brake and coupling detailWhat ships, and what it does.
The stand we built to characterise every drive we ship. Inline torque sensing, a magnetic powder brake under closed loop control, and zero backlash bellows couplings on a rigid frame. A commercial stand in this torque class typically runs several times the price. We build these to order because we already build them for ourselves.
Software and telemetry, out of the box.
This is not just a board. It ships with host software that streams real-time telemetry, tunes control loops live, and configures the drive over the bus, so you spend your time on the robot, not the bring-up.
See inside the loop
Stream phase currents, position, velocity, bus voltage and temperature in real time over CAN-FD or RS-485.
Tune without reflashing
Adjust FOC gains, limits and modes on the fly from the host tools and watch the response immediately.
Script and integrate
A clean command and telemetry protocol with a host SDK, so the drive drops into your own control stack and test rigs.